
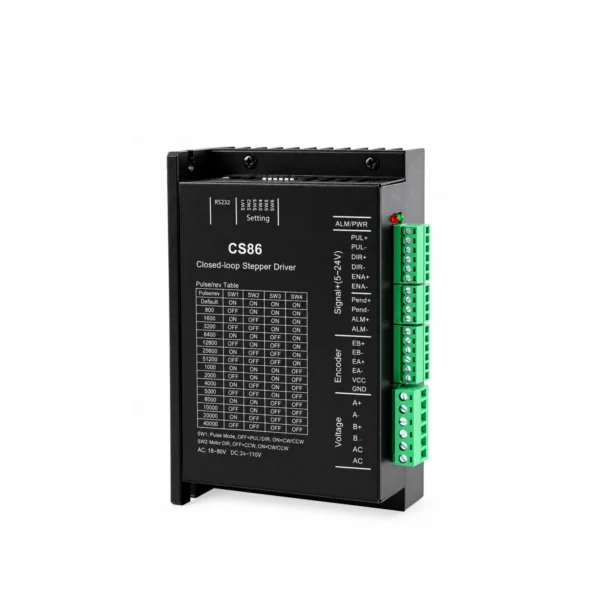
CS86 Closed-Loop Stepper Motor Driver
Closed-Loop Stepper Motor Driver for Precise Motion Control
CS86 closed-loop stepper motor driver combines microstepping control with encoder feedback for stable and responsive motion control in automation equipment.
Key Specifications
- Adjustable current up to 6.0 A
- Microstepping settings from 400 to 40,000 pulses/rev according to the documented configuration
- Pulse response frequency up to 100 kHz
- AC 18–80 V / DC 24–110 V power supply
- Supports 4-, 6- and 8-wire two-phase stepper motors
- Encoder feedback and tracking-error protection
Overview
The CS86 Closed-Loop Stepper Motor Driver is a digital stepper motor driver designed for applications requiring stable motion, precise positioning and improved motor control. It combines advanced digital control technology with encoder feedback to monitor motor operation and provide protection against tracking errors.
The driver supports adjustable current and microstepping settings, allowing the operating parameters to be configured according to different motor and motion-control requirements. Built-in microstepping technology helps improve motion smoothness and reduce vibration during operation.
With optical-isolated differential signal inputs, encoder interfaces and multiple protection functions, the CS86 is suitable for integration into small and medium-sized automation equipment, CNC systems, instruments and other motion-control applications.
Key Features
Closed-Loop Encoder Feedback
Encoder feedback allows the driver to monitor motor operation and respond to motion deviations, helping improve positioning reliability in closed-loop applications.
Smooth Microstepping Control
Built-in microstepping technology provides smoother motor operation and helps reduce vibration and mechanical noise during motion.
Adjustable Current
The driver supports adjustable static and dynamic current settings within the documented 0–6 A range, allowing the output to be matched to different stepper motor requirements.
Flexible Motor Wiring
The CS86 supports 4-, 6- and 8-wire two-phase stepper motors, providing flexibility when selecting compatible motor configurations.
Differential Control Signals
Optically isolated differential signal inputs are provided for pulse, direction and enable control, helping support reliable connection with external motion controllers.
Integrated Protection
Protection functions include overcurrent and overvoltage protection, helping protect the driver and motor during abnormal operating conditions.
Applications
The CS86 Closed-Loop Stepper Motor Driver is suitable for small and medium-sized automation equipment and motion-control systems where stable operation, precise positioning and feedback control are required.
Typical applications include:
- CNC equipment
- Engraving machines
- Wire stripping machines
- Marking machines
- Cutting equipment
- Laser equipment
- Plotters
- Automatic assembly equipment
- Industrial instruments
- Other automated motion-control systems
Technical Specifications
| Parameter | Specification |
|---|---|
| Driver Type | Closed-Loop Digital Stepper Motor Driver |
| Motor Type | Two-Phase Stepper Motor |
| Output Current | Adjustable, up to 6.0 A |
| Microstepping | Adjustable |
| Documented Microstepping Range | 400–40,000 pulses/rev |
| Pulse Response Frequency | Up to 100 kHz |
| Control Signals | Pulse, Direction, Enable |
| Signal Input | Optically isolated differential input |
| Encoder Interface | Encoder feedback input |
| Motor Connection | 4-, 6- and 8-wire |
| Power Supply | AC 18–80 V / DC 24–110 V |
| Protection | Overcurrent, overvoltage and related protection |
| Driver Dimensions | Approx. 151 × 97.5 × 52.5 mm |
| Weight | Approx. 0.5 kg |
Control Signal & Encoder Interface
The CS86 provides pulse, direction and enable interfaces for connection with external motion controllers. Its encoder interface allows feedback signals to be connected to the driver for closed-loop motor control.
| Signal | Function |
|---|---|
| PUL+ / PUL− | Pulse input |
| DIR+ / DIR− | Direction input |
| ENA+ / ENA− | Enable input |
| ALM+ / ALM− | Alarm output |
| PEND+ / PEND− | Position-reached output |
| EA+ / EA− | Encoder A-phase signal |
| EB+ / EB− | Encoder B-phase signal |
| VCC | Encoder 5 V power supply |
| GND | Encoder power ground |
| A+ / A− | Motor phase A |
| B+ / B− | Motor phase B |
| AC / AC | Driver power input |
Microstepping & Current Configuration
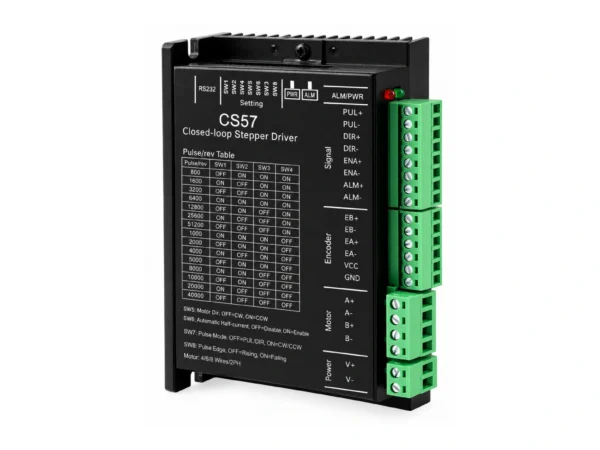
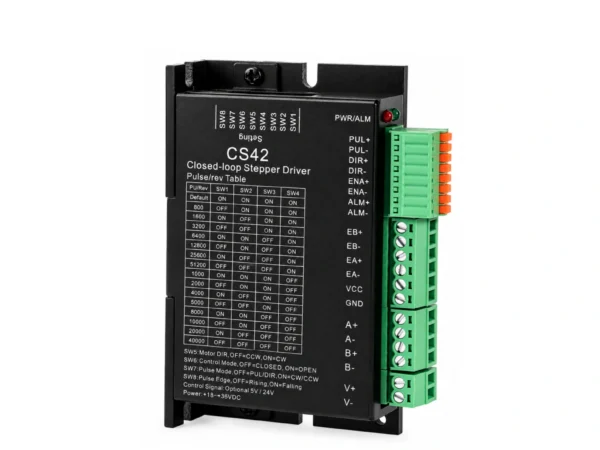
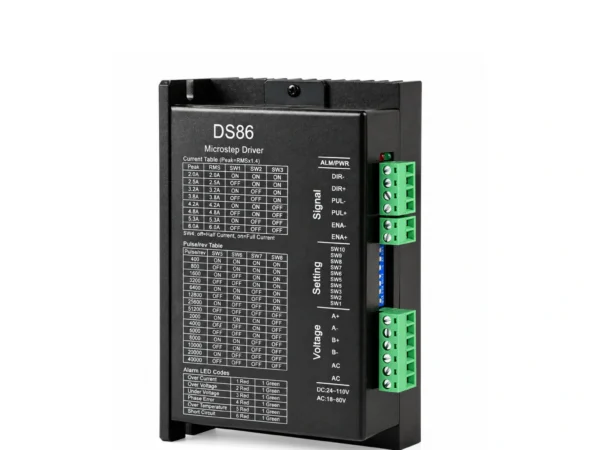
The CS86 Closed-Loop Stepper Motor Driver uses DIP switches to configure the driver operating parameters. The documented configuration provides multiple microstepping settings and current settings for different motor and motion-control requirements.
The available microstepping configurations include settings from 400 pulses/rev to 40,000 pulses/rev, while the driver current can be adjusted within the documented operating range.
For the exact DIP-switch combinations, refer to the configuration table supplied with the selected CS86 driver.
Microstepping & Current Configuration
| Parameter | Minimum | Typical | Maximum | Unit |
|---|---|---|---|---|
| Continuous Output Current | 0 | — | 6 | A |
| Input Power Voltage | AC 18 | — | AC 80 | Vac |
| Input Power Voltage | DC 24 | — | DC 110 | Vdc |
| Logic Input Current | 7 | 10 | 20 | mA |
| Pulse Frequency | 0 | — | 100 | kHz |
| Insulation Resistance | 500 | — | — | MΩ |
| Microstepping | SW1 | SW2 | SW3 | SW4 |
|---|---|---|---|---|
| 400 | ON | OFF | ON | OFF |
| 800 | OFF | ON | ON | OFF |
| 1600 | ON | ON | ON | OFF |
| 3200 | OFF | OFF | OFF | ON |
| 6400 | ON | ON | OFF | ON |
| 12800 | OFF | ON | OFF | ON |
| 25600 | ON | OFF | OFF | ON |
| 51200 | OFF | OFF | OFF | ON |
| 1000 | ON | OFF | ON | ON |
| 2000 | OFF | ON | ON | ON |
| 4000 | ON | ON | ON | ON |
| 5000 | OFF | OFF | ON | ON |
| 8000 | ON | ON | OFF | ON |
| 10000 | OFF | ON | OFF | ON |
| 20000 | ON | OFF | OFF | ON |
| 40000 | OFF | OFF | OFF | ON |
Wiring & Pin Configuration
The CS86 provides dedicated interfaces for motion control signals, encoder feedback, motor connection and power supply. The pin configuration is shown in the wiring diagram below.
Signal Interface
- PUL+ / PUL− — Pulse input
- DIR+ / DIR− — Direction input
- ENA+ / ENA− — Enable control input
- ALM+ / ALM− — Alarm output
- PEND+ / PEND− — In-position output
Encoder Interface
- EB+ / EB− — Encoder B-phase signal
- EA+ / EA− — Encoder A-phase signal
- VCC / GND — Encoder power supply
Motor Connection
- A+ / A− — Motor phase A
- B+ / B− — Motor phase B
Power Supply
- AC — AC power input
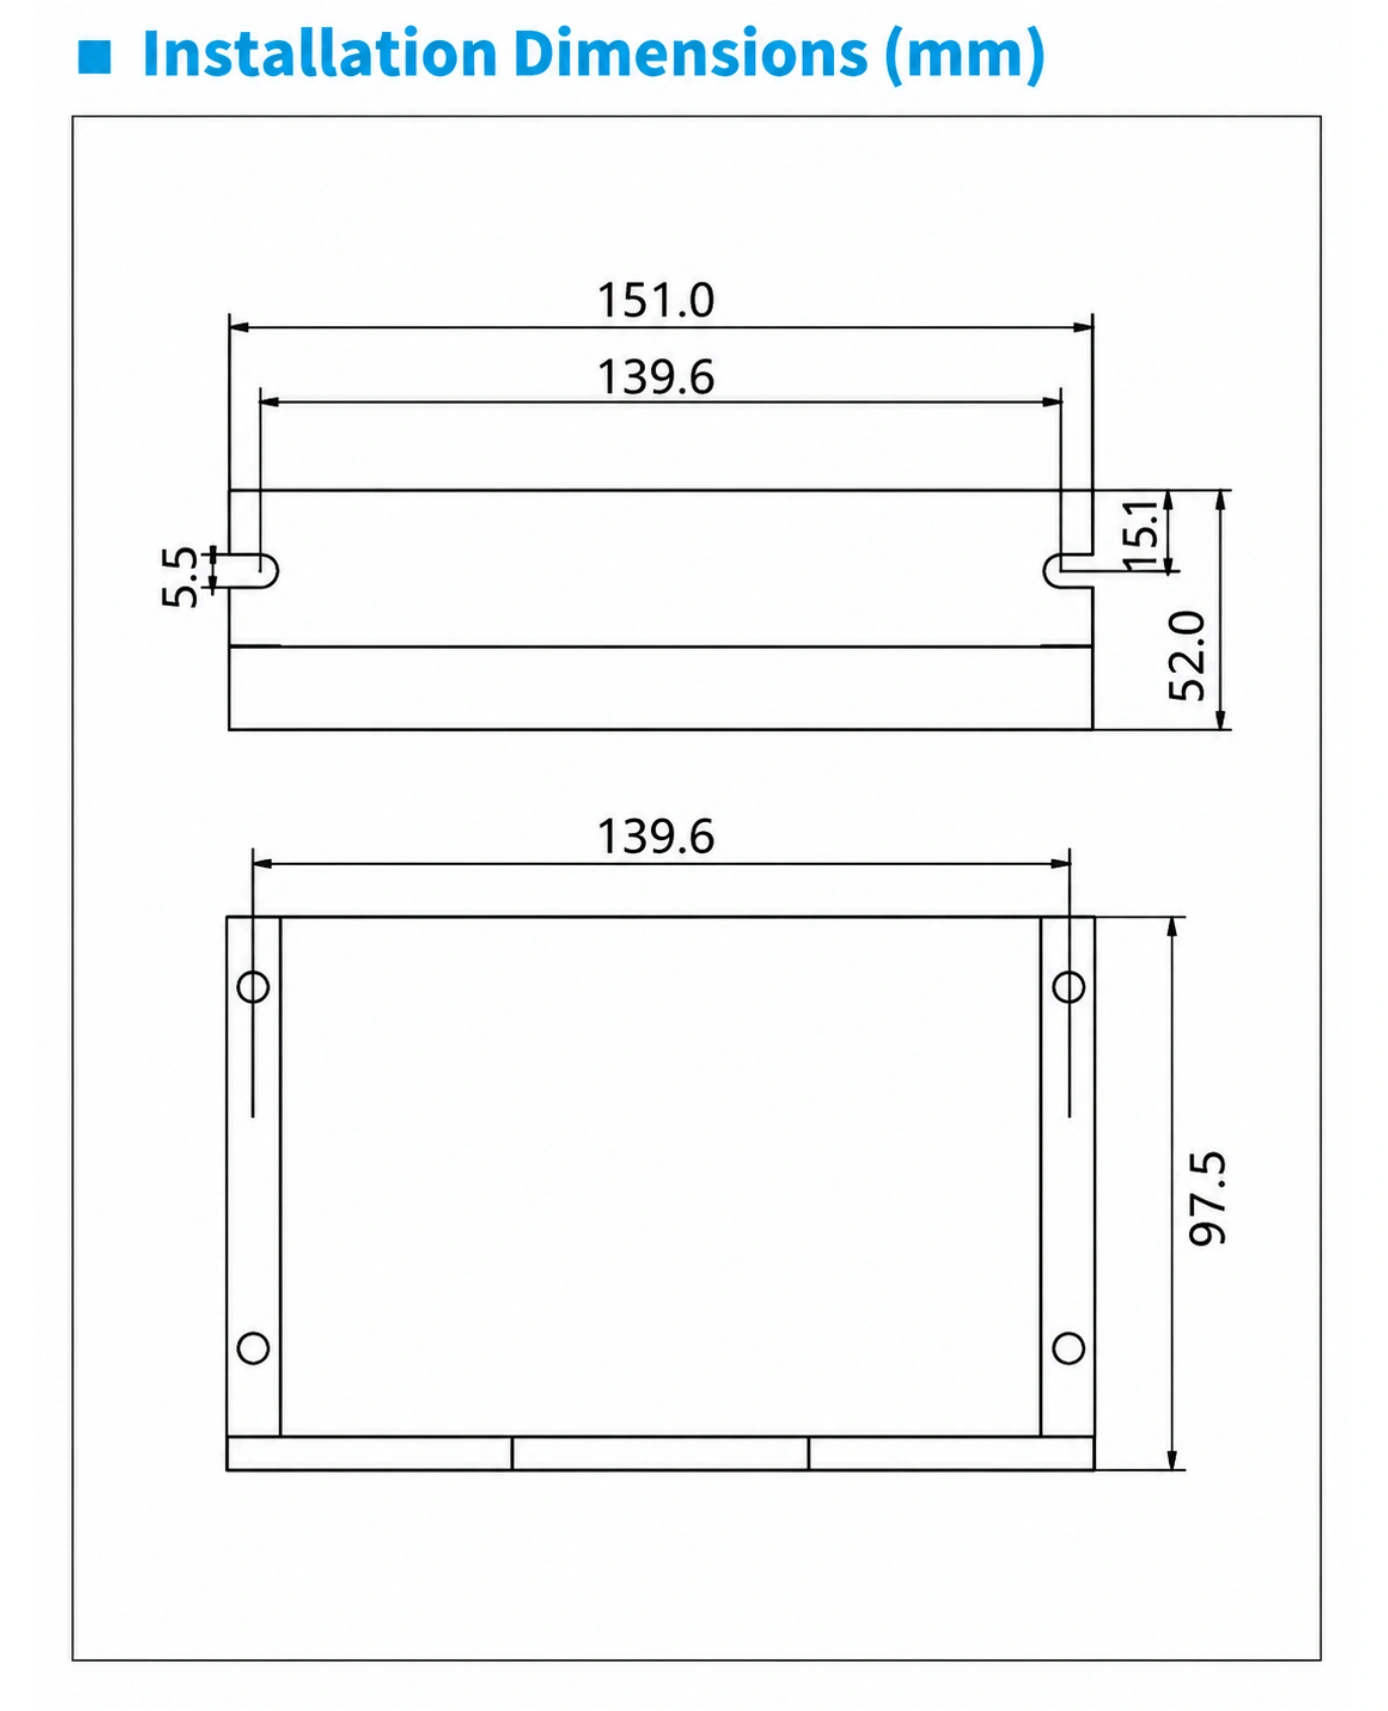
Installation Dimensions
For mechanical integration, refer to the CS86 installation drawing to confirm the overall dimensions and mounting-hole positions before installation.
Key documented dimensions include:
- Overall length: approximately 151.0 mm
- Overall height: approximately 97.5 mm
- Overall depth: approximately 52.5 mm
- Mounting dimensions: refer to the detailed installation drawing
Protection & Status Indication
The CS86 includes LED status indication for monitoring driver operating conditions and fault states.
The documented LED indications cover conditions including:
- Normal driver operation
- Overcurrent or short circuit
- Excessive input current
- Low input current
- Internal voltage fault
- Open motor phase
- Encoder fault
- Tracking error exceeding the allowable limit
This status indication helps users identify abnormal operating conditions during system commissioning and maintenance.
Why Choose the CS86 Closed-Loop Stepper Motor Driver?
Closed-Loop Motion Control
Encoder feedback enables the driver to monitor motor operation and provides an additional layer of control compared with conventional open-loop stepper systems.
Stable and Smooth Operation
Digital control and built-in microstepping technology help achieve smoother motor operation with reduced vibration.
Flexible Configuration
Adjustable current and multiple microstepping settings allow the driver to be configured for different motor and application requirements.
Built-In Protection
Overcurrent, overvoltage and tracking-error-related protection functions help improve operational reliability in automated equipment.
FAQ
1. What type of motor can the CS86 drive?
A: The CS86 is designed for compatible two-phase stepper motors and supports 4-, 6- and 8-wire motor configurations.
2. Is the CS86 an open-loop or closed-loop driver?
A: The CS86 is a closed-loop digital stepper motor driver and provides an encoder interface for feedback control.
3. What microstepping settings are available?
A: The documented configuration provides multiple settings ranging from 400 to 40,000 pulses per revolution. The exact setting is selected using the driver’s DIP switches.
4. What happens if a tracking error occurs?
A: The CS86 provides status indication and protection related to tracking errors. The specific alarm condition can be identified through the driver’s LED status indication.
评价
目前还没有评价