
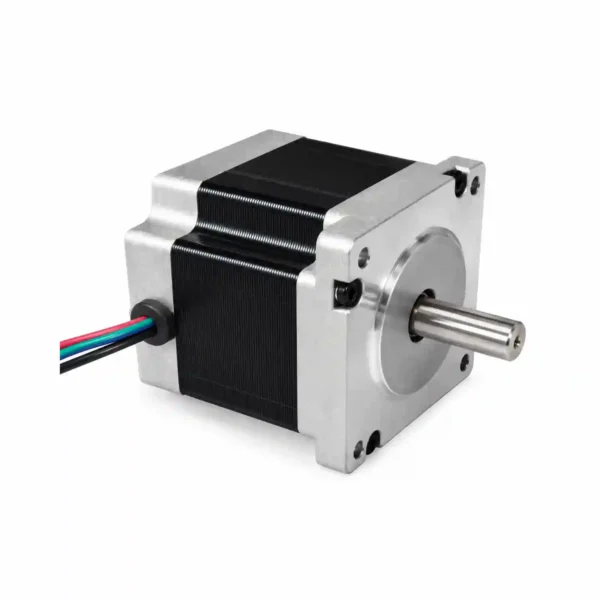
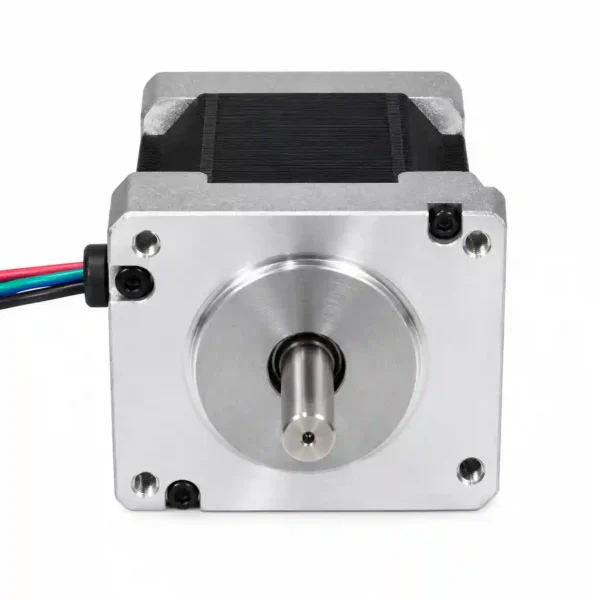
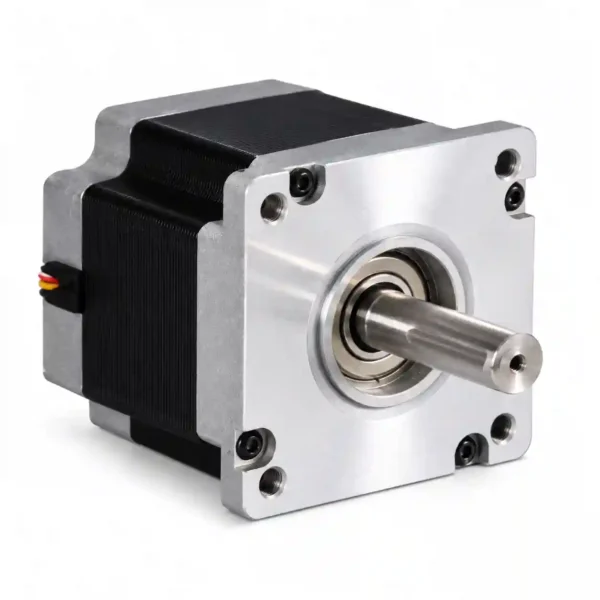
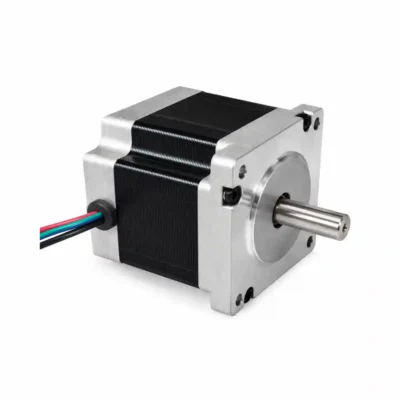
57 Series Hybrid Stepper Motor
Overview
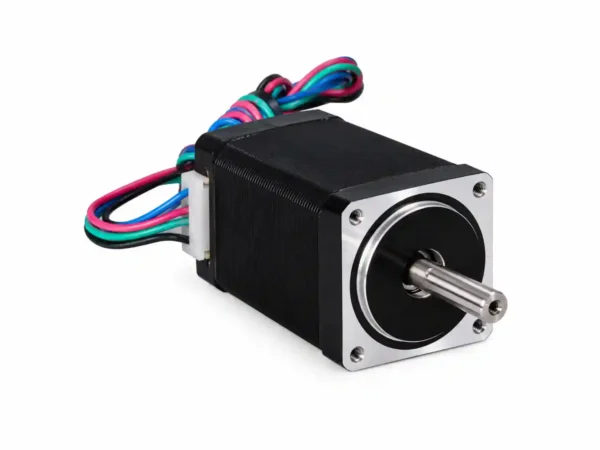
- The 57 Series Hybrid Stepper Motor is a compact motor family designed for precise rotary positioning and reliable motion control across a range of equipment and automation applications. With multiple phase configurations, wiring options, motor lengths, and holding torque levels, the series provides flexible solutions for different motion-control requirements.
Key Specifications
- Step Angle – 1.8° / 0.9° / 1.2°
- Phase Configuration – 2-phase / 4-phase
- Wiring Configuration – Plug-in / Lead-wire
- Motor Length – 39.5 mm to 100 mm
- Holding Torque – 0.34 to 3.5 N·m
- Maximum Temperature – 80°C Max
- Ambient Temperature – -20°C to +50°C
- Insulation Resistance – 100 MΩ min. @ 500 VDC
Overview
The 57 Series Hybrid Stepper Motor is designed for motion-control applications requiring higher torque and a larger motor frame than compact stepper motor series. Its 57 mm-class frame provides a practical balance between installation size, torque output, and mechanical stability.
The series includes multiple configurations with 1.8°, 1.2°, and 0.9° step angles, as well as 2-phase and 4-phase options. Different motor lengths and electrical characteristics allow the motor to be selected according to the required holding torque, speed range, and available installation space.
Depending on the configuration, the 57 Series is available with plug-in or lead-wire connections, making it suitable for different equipment wiring and integration requirements.
Key Features
1.Multiple Step-Angle Options
The 57 Series includes 1.8°, 1.2°, and 0.9° step-angle configurations, providing options for different positioning and motion-control requirements.
2. Wide Torque Range
Different motor lengths and electrical configurations provide a broad range of holding torque options, with selected models reaching up to 3.5 N·m.
3. 2-Phase and 4-Phase Configurations
Both 2-phase and 4-phase configurations are available across different models, allowing the motor to be matched with different drive and control requirements.
4. Multiple Motor Lengths
The series covers a range of motor lengths, allowing users to select a compact configuration or a longer motor when higher torque is required.
5. Flexible Wiring Options
Depending on the model, the motor can use plug-in or lead-wire configurations, simplifying integration into different equipment designs.
6. Suitable for Industrial Motion Control
The 57 Series is suitable for applications requiring repeatable positioning, controlled rotary motion, and stable torque performance.
Applications
The 57 Series Hybrid Stepper Motor can be used in a variety of motion-control and automation applications, including:
- Industrial automation equipment
- CNC and positioning systems
- Linear motion systems
- Automated machinery
- Printing and labeling equipment
- Pick-and-place mechanisms
- Packaging equipment
- Instrumentation and control equipment
- Robotics and mechanical positioning systems
Technical Specifications
The 57 Series Hybrid Stepper Motor is available in multiple configurations to meet different motion-control requirements. The series includes 1.8°, 0.9°, and 1.2° step-angle options, with different electrical characteristics, holding torque, motor lengths, and wiring configurations.
General Specifications
| Parameter | Specification |
|---|---|
| Step Angle | 1.8° / 1.2° / 0.9° |
| Step Angle Tolerance | ±5% |
| Phase Configuration | 2-phase / 4-phase |
| Wiring Configuration | Plug-in / Lead-wire |
| Maximum Temperature | 80°C Max |
| Ambient Temperature | -20°C to +50°C |
| Insulation Resistance | 100 MΩ min. @ 500 VDC |
| Dielectric Strength | 500 VAC for 1 minute |
| Resistance Tolerance | ±10% |
| Inductance Tolerance | ±20% |
| Holding Torque | Model-dependent, up to 3.5 N·m |
| Motor Length | Model-dependent, approx. 39.5–102 mm |
Model Specifications
The 57 Series includes different motor configurations with varying current, resistance, inductance, holding torque, motor mass, and motor length. Refer to the model tables below when selecting a motor for a specific motion-control application.
57HJA Series — 1.8° Step Angle
| Model | Step Angle | Number of Phases | Current / Phase (A) | Resistance / Phase (Ω) | Inductance / Phase (mH) | Holding Torque (mN·m) | Rotor Inertia (g·cm²) | Wiring Diagram | Motor Mass (kg) | Motor Length (mm) |
|---|---|---|---|---|---|---|---|---|---|---|
| 57HJA441-21 | 1.8° | 2 | 1.0 | 10.5 | 16 | 500 | 120 | a | 0.46 | 41 |
| 57HJA446-25 | 1.8° | 2 | 0.9 | 12.5 | 20 | 750 | 185 | a | 0.52 | 46 |
| 57HJA451-28 | 1.8° | 2 | 0.9 | 12.5 | 25 | 900 | 275 | a | 0.65 | 51 |
| 57HJA455-28 | 1.8° | 2 | 1.1 | 10 | 33 | 1100 | 310 | a | 0.71 | 55 |
| 57HJA641-25 | 1.8° | 4 | 2.0 | 1.5 | 1.6 | 390 | 120 | b | 0.46 | 41 |
| 57HJA651-21 | 1.8° | 4 | 1.1 | 6.8 | 8.5 | 720 | 275 | b | 0.65 | 51 |
| 57HJA655-25 | 1.8° | 4 | 1.0 | 8.0 | 11 | 1010 | 310 | b | 0.71 | 55 |
57HJB Series — 1.8° Step Angle
| Model | Step Angle | Number of Phases | Current / Phase (A) | Resistance / Phase (Ω) | Inductance / Phase (mH) | Holding Torque (mN·m) | Rotor Inertia (g·cm²) | Wiring Diagram | Motor Mass (kg) | Motor Length (mm) |
|---|---|---|---|---|---|---|---|---|---|---|
| 57HJB451-21 | 1.8° | 2 | 2.0 | 0.9 | 3.0 | 750 | 275 | a | 0.65 | 51 |
| 57HJB455-30 | 1.8° | 2 | 2.0 | 1.8 | 6.3 | 800 | 310 | a | 0.71 | 55 |
| 57HJB478-26 | 1.8° | 2 | 4.0 | 0.6 | 2.2 | 2100 | 470 | a | 1.10 | 78 |
| 57HJB4 100-28 | 1.8° | 2 | 4.0 | 0.7 | 2.3 | 3500 | 620 | a | 1.25 | 100 |
| 57HJB641-21 | 1.8° | 4 | 2.0 | 1.5 | 1.5 | 400 | 120 | b | 0.46 | 41 |
| 57HJB655-25 | 1.8° | 4 | 3.0 | 0.7 | 1.2 | 900 | 310 | b | 0.71 | 55 |
| 57HJB663-25 | 1.8° | 4 | 3.0 | 4.0 | 6.4 | 1200 | 350 | b | 0.80 | 63 |
| 57HJB678-30 | 1.8° | 2 | 3.0 | 1.2 | 2.2 | 1500 | 470 | b | 1.10 | 78 |
57HJC Series — 0.9° Step Angle
| Model | Step Angle | Number of Phases | Current / Phase (A) | Resistance / Phase (Ω) | Inductance / Phase (mH) | Holding Torque (mN·m) | Rotor Inertia (g·cm²) | Wiring Diagram | Motor Mass (kg) | Motor Length (mm) |
|---|---|---|---|---|---|---|---|---|---|---|
| 57HJC441-21 | 0.9° | 2 | 2.5 | 0.8 | 2.3 | 500 | 120 | a | 0.46 | 41 |
| 57HJC455-25 | 0.9° | 2 | 3.0 | 1.0 | 4.6 | 1200 | 310 | a | 0.71 | 55 |
| 57HJC478-26 | 0.9° | 2 | 2.6 | 1.2 | 6.0 | 1700 | 470 | a | 1.10 | 78 |
| 57HJC641-21 | 0.9° | 4 | 1.1 | 6.0 | 8.6 | 400 | 120 | b | 0.46 | 41 |
| 57HJC655-23 | 0.9° | 4 | 1.0 | 7.5 | 18 | 900 | 310 | b | 0.71 | 55 |
| 57HJC678-20 | 0.9° | 4 | 3.0 | 1.0 | 1.6 | 1300 | 470 | b | 1.10 | 78 |
57HJD Series — 1.2° Step Angle
| Model | Step Angle | Number of Phases | Current / Phase (A) | Resistance / Phase (Ω) | Inductance / Phase (mH) | Holding Torque (mN·m) | Rotor Inertia (g·cm²) | Wiring Diagram | Motor Mass (kg) | Motor Length (mm) |
|---|---|---|---|---|---|---|---|---|---|---|
| 57HJD341-21 | 1.2° | 2 | 5.2 | 0.24 | 0.23 | 450 | 110 | a | 0.45 | 41 |
| 57HJD355-25 | 1.2° | 2 | 5.6 | 0.7 | 0.9 | 900 | 300 | a | 0.75 | 55 |
| 57HJD378-25 | 1.2° | 2 | 5.5 | 1.05 | 1.1 | 1500 | 480 | a | 1.10 | 78 |
| 57HJD3102-32 | 1.2° | 4 | 5.5 | 0.38 | 0.5 | 2000 | 530 | a | 1.57 | 102 |
Dimensions & Wiring
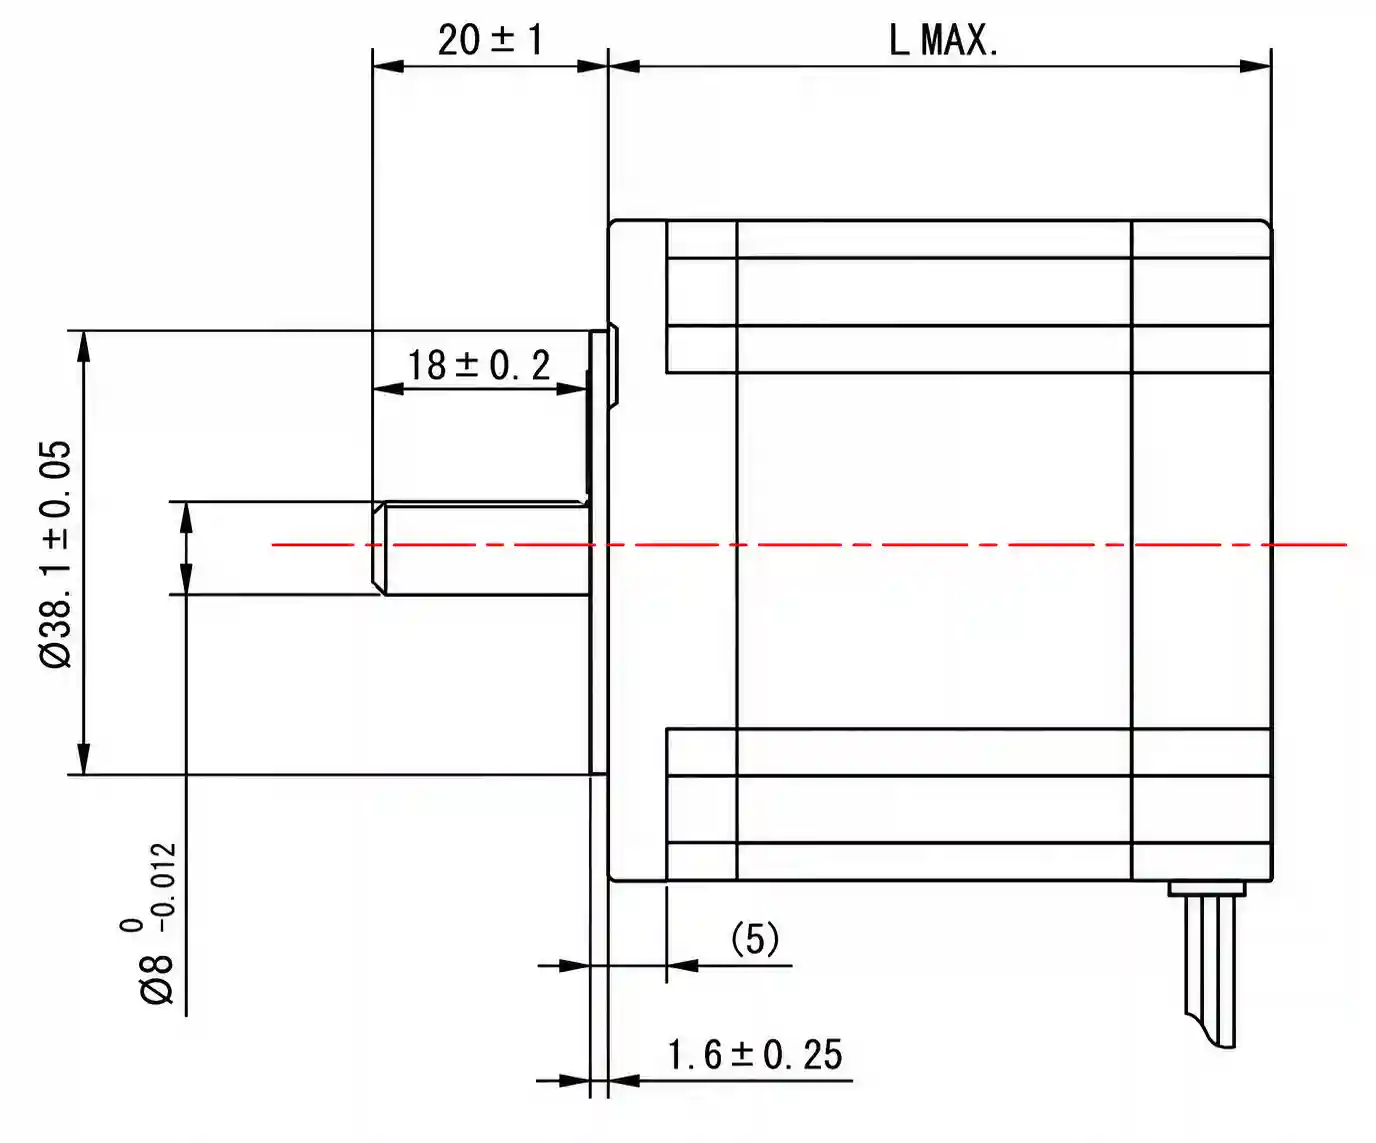
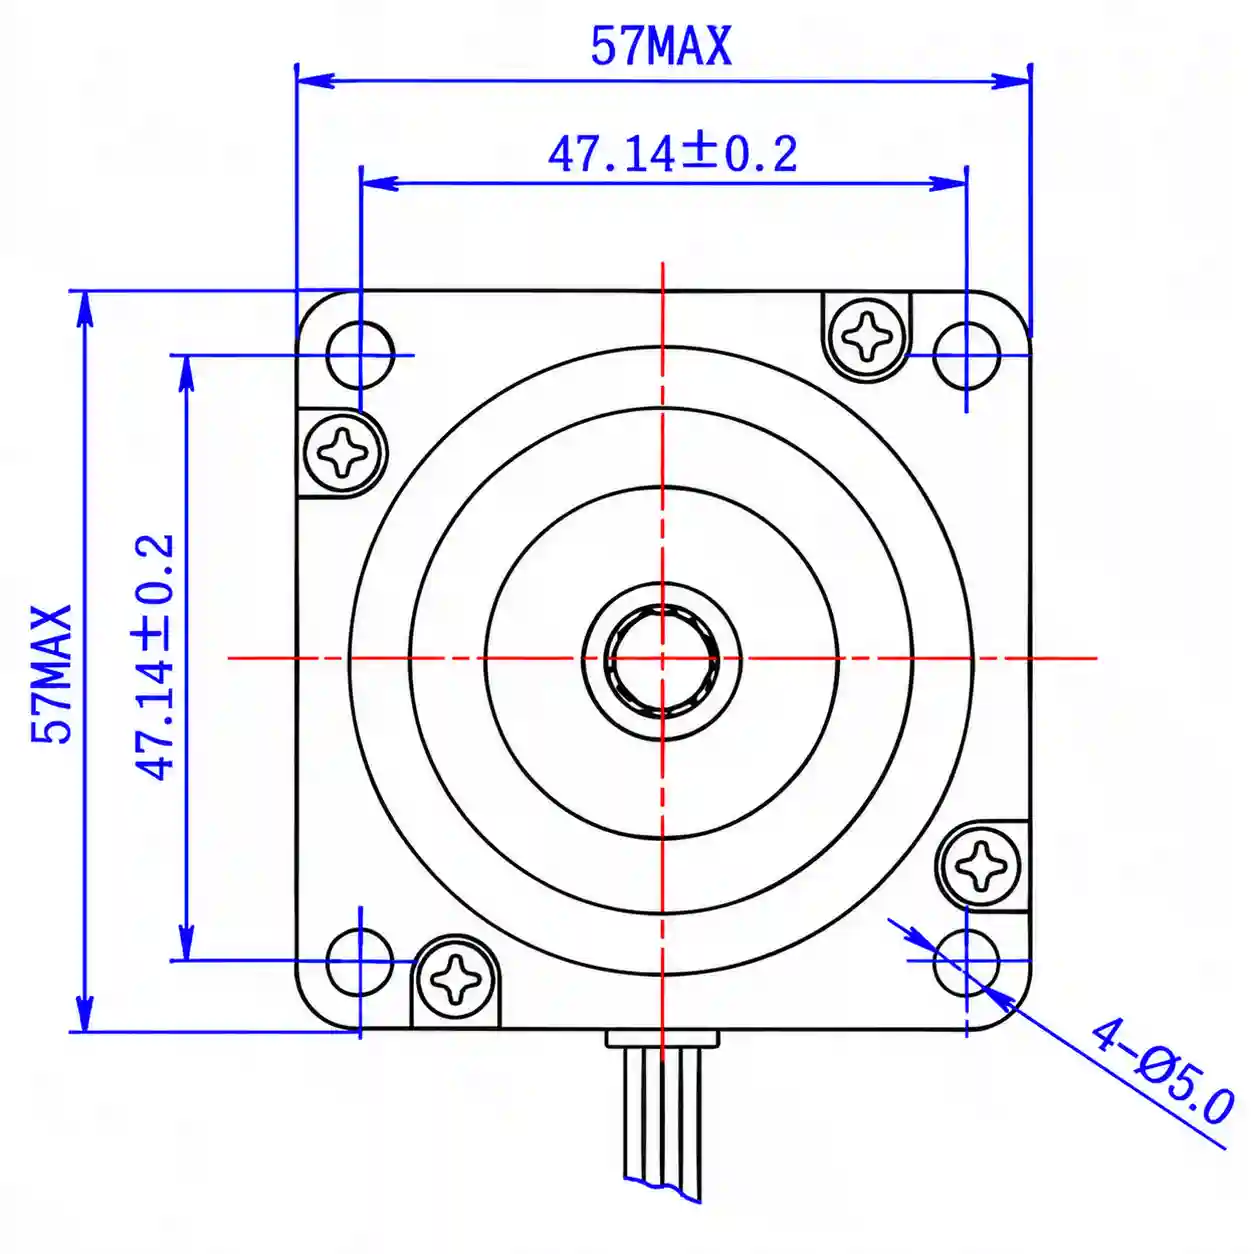
Refer to the dimensional drawings and wiring information when selecting and integrating the 57 Series Hybrid Stepper Motor into your equipment. The drawings provide key information on the motor frame dimensions, shaft dimensions, mounting holes, overall length, and wiring configuration.
Torque-Speed Characteristics
The torque-speed curves below show representative performance characteristics of selected 57 Series Hybrid Stepper Motor models under specified test conditions. Actual torque performance may vary depending on the motor model, drive, supply voltage, current, operating speed, and other operating conditions.
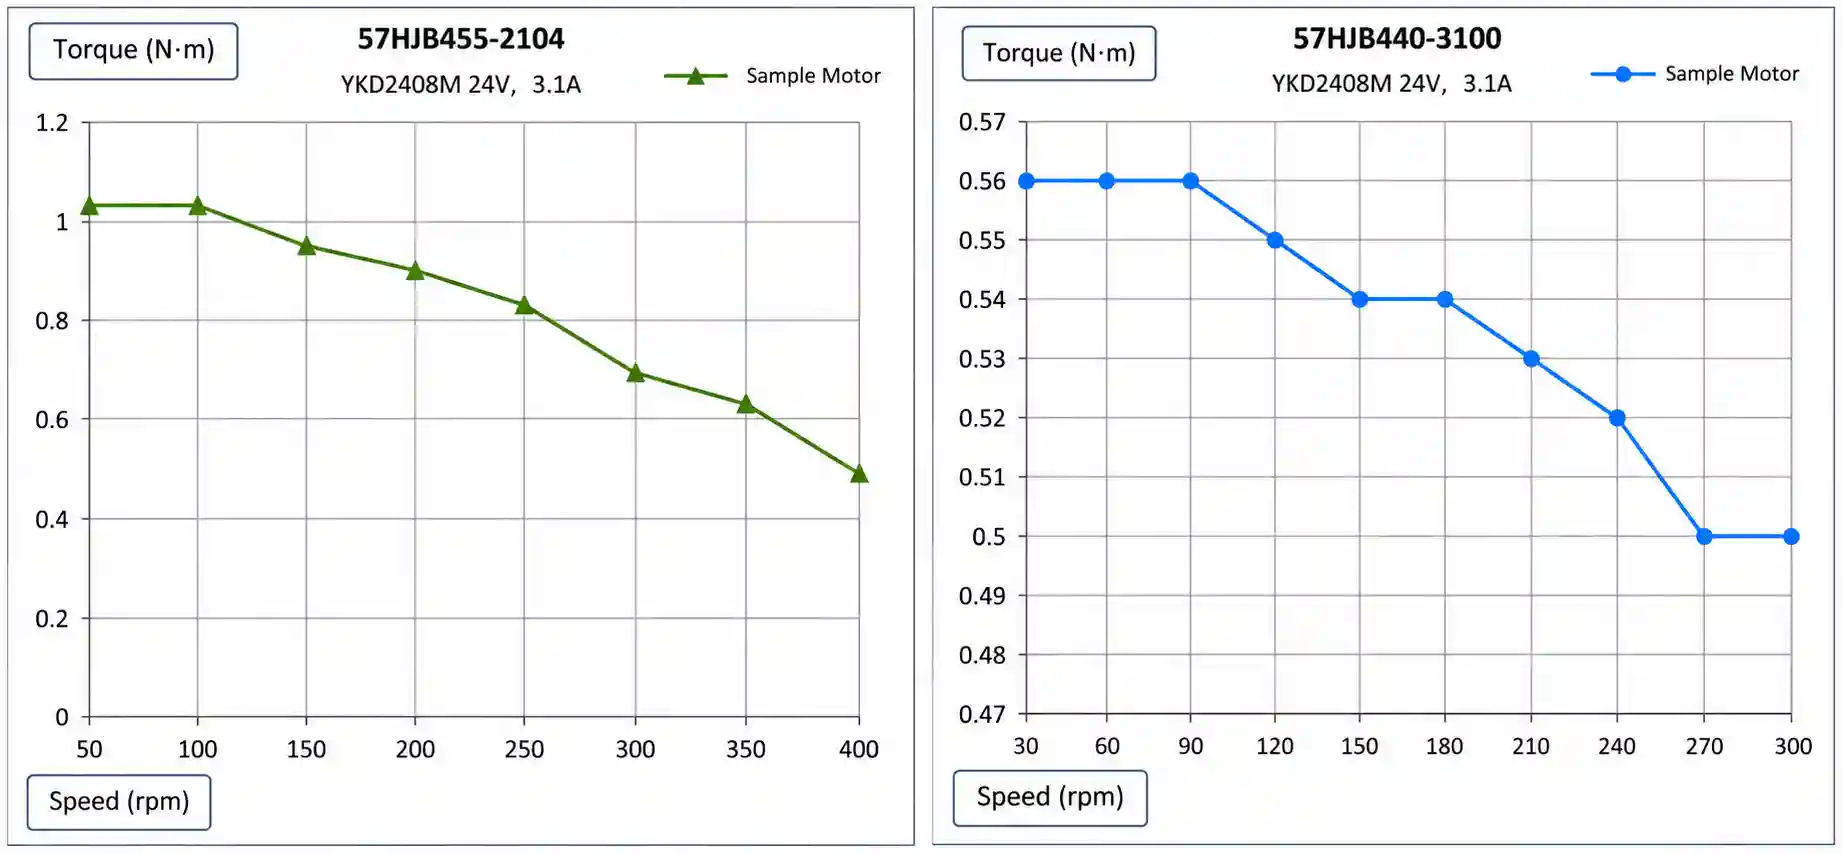
Representative torque-speed curves for reference. Please contact us for detailed performance data of the specific motor model.
Why Choose the 57 Series?
The 57 Series provides a practical solution when an application requires more torque and mechanical capacity than compact stepper motors, while still maintaining the controllability and positioning characteristics of a hybrid stepper motor.
Its range of step angles, phase configurations, motor lengths, and wiring options makes it easier to select a configuration that matches the mechanical and electrical requirements of the equipment.
FAQ
1. What step angles are available for the 57 Series Hybrid Stepper Motor?
A: The 57 Series is available with 1.8°, 1.2°, and 0.9° step-angle configurations, depending on the specific model.
2. Can I choose between 2-phase and 4-phase configurations?
A: Yes. The series includes both 2-phase and 4-phase models. The appropriate configuration should be selected according to the compatible stepper motor driver and the application’s electrical requirements.
3. How do I select the right 57 Series motor?
A: Selection should be based on the required holding torque, operating speed, step angle, rated current, motor length, and wiring configuration. If you provide your required torque and operating conditions, the appropriate model can be recommended.
评价
目前还没有评价